AI Fundamentals
What are Nanobots? Understanding Nanobot Structure, Operation, and Uses

 Add Unite.AI to your preferred sources on Google
Nanobot is a popular label for extremely small machines, but it is often used too loosely. A true nanoscale device has critical dimensions measured in nanometers. Many research systems described as nanorobots are actually microrobots, micro/nanomotors or particles whose overall size is measured in micrometers.
These devices do not resemble miniature metal humanoids. They may be engineered particles, flexible swimmers, catalytic motors, magnetic structures or molecular assemblies designed to move, sense, release a payload or interact with a biological environment.
Key takeaways
- Nanorobots, microrobots and molecular machines occupy different size ranges and use different control mechanisms.
- Propulsion can be magnetic, acoustic, optical, chemical or driven by a surrounding fluid.
- Navigation combines external fields, imaging, sensing and feedback; fully autonomous clinical nanobots are not routine medicine.
- Biocompatibility, retrieval, immune response, dose control and scalable manufacturing are as important as movement.
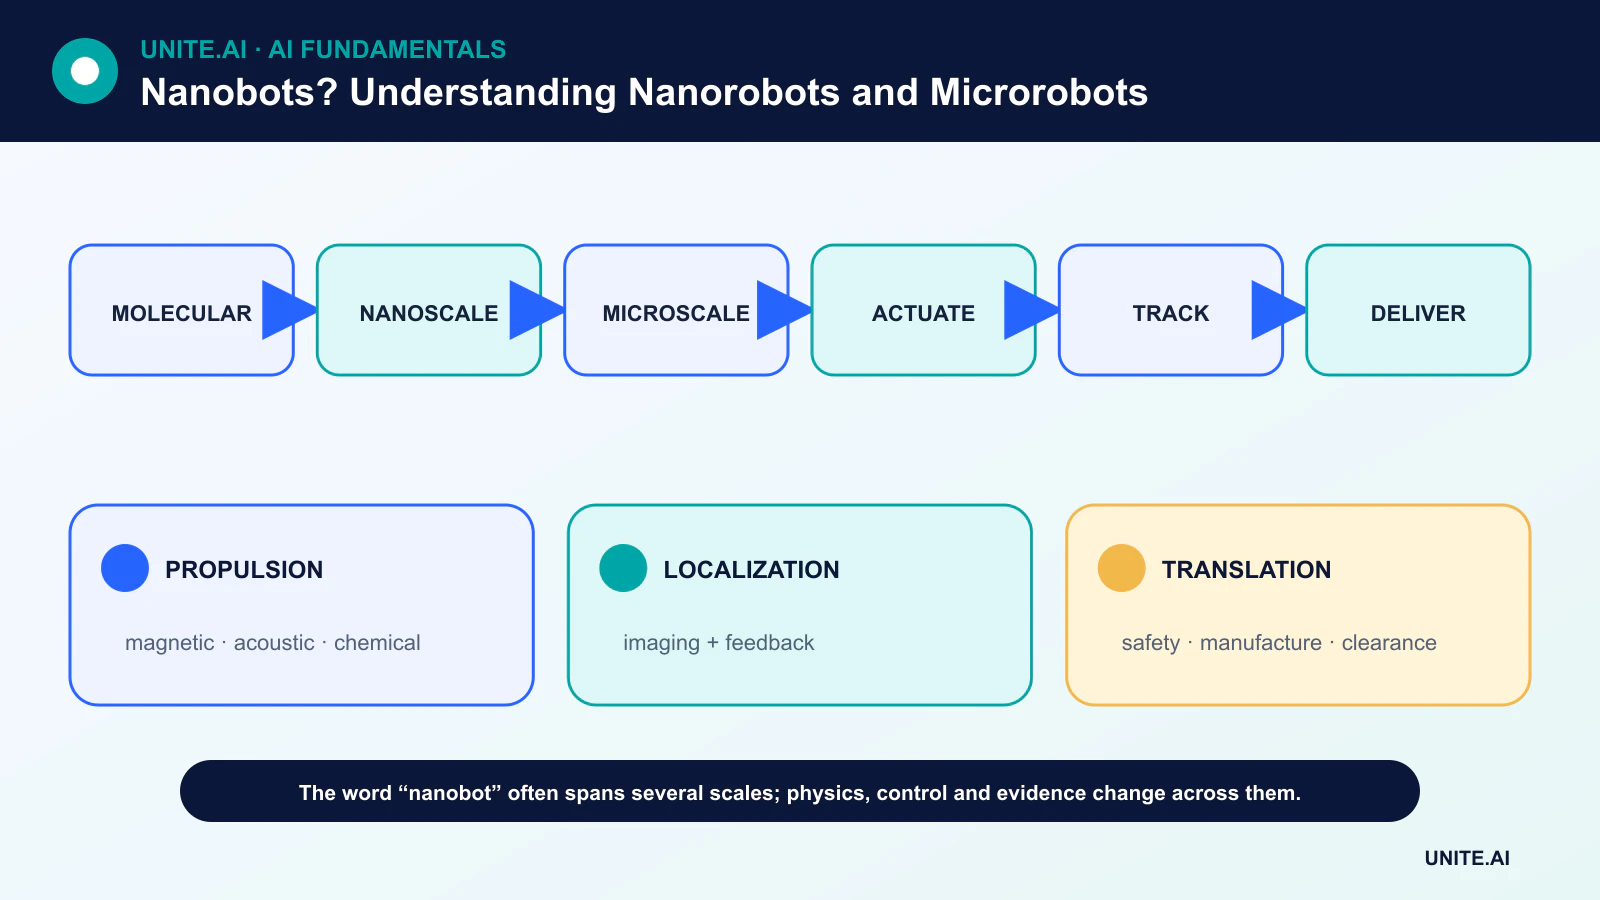
A scale ladder, not one device category
A nanometer is one billionth of a meter; a micrometer is one millionth. Molecular machines may be only a few nanometers, while many controllable biomedical swimmers are tens or hundreds of micrometers. The distinction matters because forces, fabrication techniques and imaging methods change with scale.
At very small scales, inertia is negligible and viscous forces dominate. Thermal motion can disrupt orientation. A design that works for a millimeter robot cannot simply be shrunk; propulsion and control must be redesigned for the physics of the target environment.
Fabrication and materials
Micro/nanorobots can be fabricated with lithography, electrodeposition, self-assembly, two-photon polymerization or particle synthesis. Common materials include polymers, magnetic metals, silica and biodegradable compounds. The choice affects actuation, imaging contrast, payload capacity and clearance from the body.
A biomedical design must also consider toxicity and degradation products. A promising motion demonstration in a laboratory fluid is only one step toward a system that can be sterilized, manufactured consistently and used without causing harmful inflammation or accumulation.
How tiny robots move
Magnetic systems use external fields to pull, rotate or steer embedded magnetic material. Acoustic systems use ultrasound and pressure fields. Light can drive photosensitive materials, while catalytic motors convert chemical energy into motion. Biological propulsion can harness bacteria or cells.
Each method has limits. Magnetic fields can penetrate tissue but require external equipment; optical control is constrained by scattering and depth; chemical fuels may be unsuitable in vivo. Flow in blood vessels or the gastrointestinal tract can overwhelm weak propulsion.
Sensing, navigation and control
Navigation may combine ultrasound, magnetic resonance, X-ray, fluorescence or other imaging with an external controller. A feedback loop estimates position, chooses a control signal and checks the result. Computer vision can assist tracking, while reinforcement learning may be studied for control in simulation or constrained experiments.
Calling a device autonomous should be specific: does it follow a chemical gradient, execute onboard logic, or merely respond to a field? Most tiny devices have extremely limited onboard power and computation, so intelligence often resides in external imaging and control equipment.
Biomedical uses and the clinical gap
Research targets include localized drug delivery, minimally invasive sampling, thrombus treatment, biofilm disruption and microsurgery. Local delivery could raise concentration at a target while reducing systemic exposure, but it also demands accurate dosing, containment and proof that devices can be cleared or retrieved.
Clinical translation requires reproducible manufacturing, long-term safety, robust navigation in realistic anatomy and regulatory evidence. Readers should treat dramatic animations as concepts unless supported by peer-reviewed in-vivo results and clearly stated device scale.
What nanobots are—and what the term often obscures
A nanometer is one billionth of a meter, but many systems described as nanobots are micro- or nanoscale particles, capsules, DNA structures, magnetic swimmers, or chemically powered machines rather than autonomous robots with processors and motors. At these scales, viscosity, Brownian motion, surface forces, diffusion, and molecular interactions dominate inertia. A credible description should specify dimensions, material, propulsion or transport mechanism, sensing, control, payload, and whether operation has been demonstrated in vitro, in animals, or in humans.
Nanomachines can be passive carriers that release cargo under pH, temperature, enzyme, light, ultrasound, or magnetic conditions; active structures may move through external magnetic fields, catalytic reactions, biological motors, or shape changes. Power and communication are difficult, so control is often external or encoded in material response. Fabrication can use lithography, self-assembly, DNA origami, nanoparticles, or hybrid biological components. Each method trades precision, scale, biocompatibility, payload, and reproducibility.
Medical delivery, measurement, and safety
Targeted drug delivery aims to concentrate therapy at disease sites and reduce systemic exposure. Evidence must measure biodistribution, circulation time, cellular uptake, release kinetics, clearance, toxicity, immune response, and therapeutic outcome—not merely that particles accumulate near a tumor in one model. The enhanced permeability and retention effect varies among tumors and patients. Navigation through blood, mucus, tissue, and cellular barriers creates separate failure points, and an external field that works in a small animal may not scale to a human body.
Manufacturing requires tight control of size distribution, surface chemistry, contamination, payload, aggregation, and storage. Materials or degradation products can trigger inflammation, clotting, organ accumulation, or environmental persistence. Regulators evaluate the complete product and use, not the futuristic label. Monitoring and retrieval may be impossible after administration, making dose limits and fail-safe degradation important. Claims of autonomous diagnosis or repair require evidence for sensing specificity, false actions, control, and long-term outcomes.
How to assess a nanobot claim
Check the peer-reviewed experiment, scale bar, control group, sample size, and operating environment. Ask what supplies energy, how commands reach the device, how position is known, and what happens after the task. Distinguish simulated trajectories from physical experiments and animal feasibility from clinical benefit. Nanotechnology has real value in materials, diagnostics, and delivery, but present capabilities remain constrained by physics, manufacturing, biology, and safety. The more a claim resembles a tiny science-fiction robot, the more carefully its actual mechanism should be inspected.
Worked example: assessing a magnetic drug-delivery microrobot
Researchers report a magnetic helical structure that carries a drug in a fluid channel. A rigorous assessment verifies its actual micrometer dimensions, fabrication variation, field strength, speed, steering accuracy, payload, release, and behavior in blood-like viscosity. Controls compare free drug, passive carrier, and magnetic device. Results from a transparent channel are not described as navigation through a human vessel without tissue, immune, and scale evidence.
The next studies measure biodistribution, clearance, toxicity, heating, aggregation, and therapeutic effect in validated models. The external controller’s localization and failure behavior are part of the system. Manufacturing must reproduce size and coating, and material degradation is tracked. Claims distinguish simulation, in vitro, animal, and clinical stages. The term ‘nanobot’ is avoided if the device is a remotely actuated microrobot, because precise language helps readers understand both the engineering achievement and remaining barriers.
Implementation evidence and operational readiness
A production decision needs more than a successful demonstration. Define the intended users, operating environment, inputs, outputs, dependencies, owner, and the consequence of each important failure. Establish a reproducible baseline and a versioned evaluation set before tuning. Test ordinary cases, boundary conditions, malformed or missing input, distribution shift, dependency outage, misuse, and the groups or environments most likely to be underserved. Measure task quality together with calibration or uncertainty, latency, throughput, resource cost, accessibility, privacy, and security. Record every transformation and threshold so an independent reviewer can reproduce the result and distinguish evidence from an attractive prototype.
Before launch, assign authority for release, exceptions, changes, rollback, and retirement. Use a staged rollout, preserve a safe fallback, and verify monitoring with deliberately injected failures. Operational telemetry should reveal input quality, output behavior, model or rule version, dependency health, human overrides, and confirmed outcomes without collecting unnecessary sensitive data. Define alert thresholds and a response owner, then review real-world evidence after deployment rather than assuming offline performance will persist. Reevaluate whenever data sources, users, models, vendors, policies, hardware, or objectives change. A maintained system also needs documented recovery, incident learning, deletion and retention procedures, and a clear point at which it should be disabled or replaced.
Frequently asked questions
Are nanobots already swimming through patients?
Tiny drug-delivery particles and some microdevice research exist, but general-purpose autonomous nanobots are not routine clinical technology.
Do nanobots contain conventional computers?
Usually not. At these scales, control is commonly external or emerges from material, chemical or molecular behavior rather than a miniature CPU and battery.
Primary references